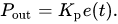Wednesday, June 01, 2022

Lego 51515 - Tricky - Understanding the line following code

One of the activities one can code with the Tricky bot is the line follower. But how does the line following code work?

Here is the line following code that tricky uses:
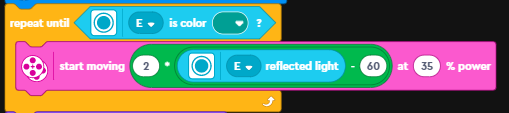

The first line is controls the loop execution and run the line following code until the sensor senses the green piece that is part of the basket.

But what is the the code within the loop doing? In a word: Propotional Line Following Algorithm (ok 4 words!)

Lets break down the code into its various bits:
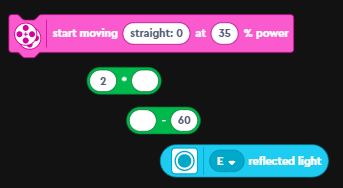
the various bits in that one line of code. order of operations is bottom up


  1. The code uses the sensor in "reflected light" mode. In this mode, the color sensor reports back the amount of light being reflected back to the sensor. Remember dark colors reflect less light compared to light colors.
  2. Next up is the subtract block. The sensor value is one of the operands and the other operand here (the 60) is the target value.

    The idea here is that we want the robot to try and get to the target reflected light value of 60. If it senses more, than it needs to reduce it and if its less, then it needs to increase it. One can call this the "error" value.

  3. The next block is a multiply block. It multiplies the "error" by a constant (in this case 2). One can consider this entire expression upto here, as the "correction value". Here is the complete line:


  4. Next up is the "start moving with steering at power" block. It will move the robot at the specified power (35%) and at the angle defined in the first field. The value we will use for the angle is the "correction value" that we calculated previously. This is what the final line looks like:
How does it all work?
First lets look at how start moving block works. The first input to the block is the direction in which the robot is supposed to move. The values it can take are -100 to 100 (negative values = Left, positive values = Right, 0 = Straight).
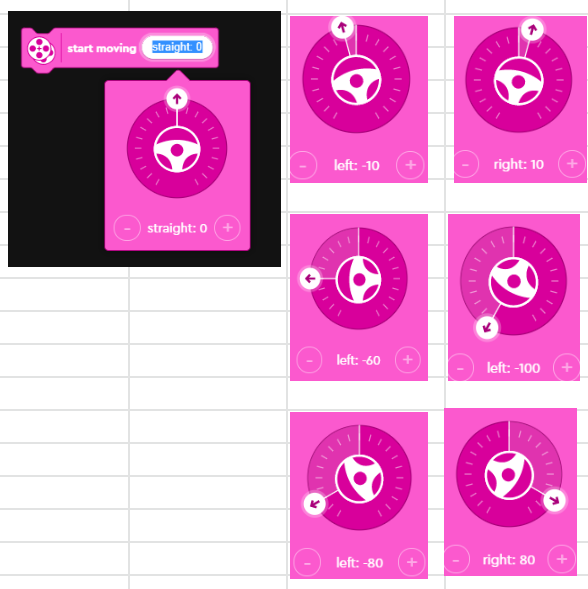
The sensor outputs a value between 0 and 100 (0 on black, 100 on white).


The line following algorithm tries to follow the edge of the line, as this is a lot more reliable, than trying to stay completely on the white or on the black part of the line. You should try this as an exercise with your robot (Set target to 0)

Here are the different values for the output angle based on a target value of 60.
Target60
Kp2
SensorErrorAngle CalculationAngleDirection
5552 x (55 - 60)-10Left
65-52 x (65 - 60)10Right
6002 x (60 - 60)0Straight
70-102 x (70 - 60)20Right
80-202 x (80 - 60)40Right
50102 x (50 - 60)-20Left
40202 x (40 - 60)-40Left
100-402 x (100 - 60)80Right
0602 x (0 - 60)-120Left

One thing to note is that with a target value = 60 and Kp = 2, the robot will follow the line when placed on the left side of the line. This is because, values above 60 (more white), will make the robot turn right (towards the line) and values below 60 (more black), will make the robot turn left. If you wanted the robot to travel on the right side of the line what do you think you will have to change? (see answer at the bottom). 

You can play with the above calculations using Google Sheets: https://docs.google.com/spreadsheets/d/1RHkM3w1KmZSh7D-QXvpsda7rRfRzInH4p_jKrHQJQg0/edit?usp=sharing

When you use this piece of code, you might have to change the value of the target (in this case 60) and the multiplier. 

Summary:

Why is this called a proportional line follower? As the robot drifts away from the line, the error value will become larger. We make this error value even larger by using a constant as a multiplier. This error value is then used as the angle to turn the robot. So the larger the difference, the bigger the angle that will applied for steering. Hence the proportional line follower!

So where does the math for all of this come from? There is a concept called PID: Proportional-Integral-Derivative and this concept is used in a lot robotic controllers. In the line-follower, we used just the proportional component of the math. PID uses the following complicated looking formula: 
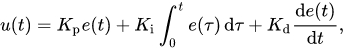
We used just the first term of the above equation in our code:
If you want to learn more about how PID is used and implemented and the math, read this post of mine: Error Correction using PID (Proportional Integral Derivative) - The Math

You can also learn more about PID here: PID controller - Wikipedia

Answer:
To make the robot travel on the right side of the line, you will have to reverse the output angles. The easiest way to do this is to change the sign of Kp. You would set Kp = -2.


Wednesday, May 18, 2022

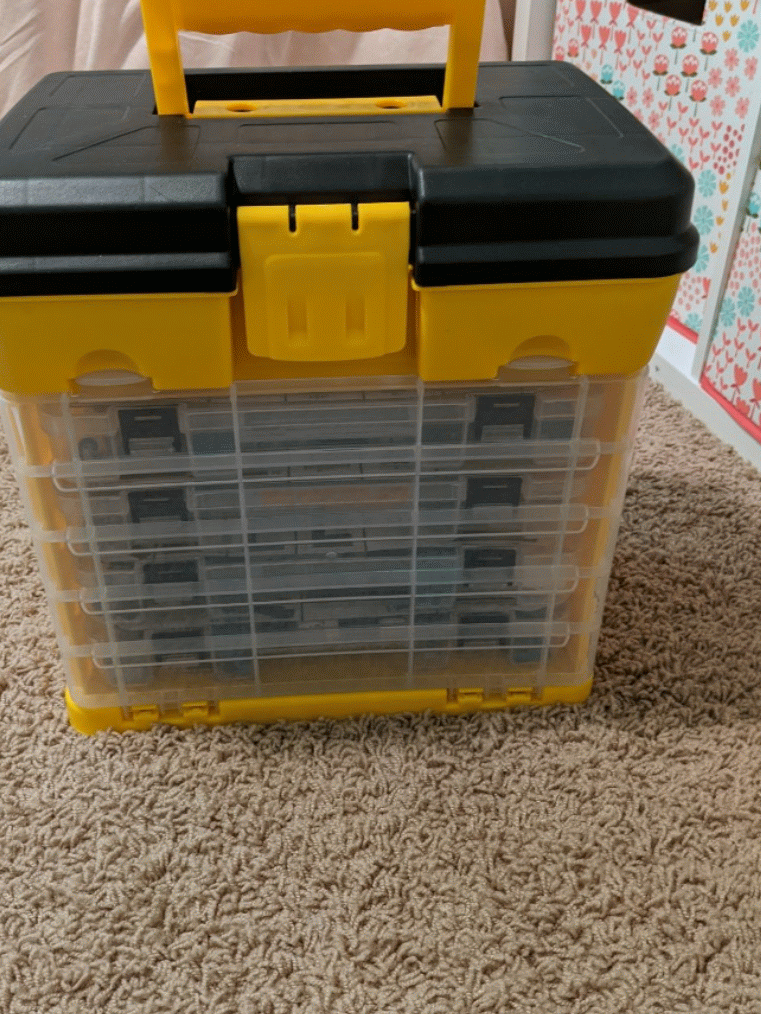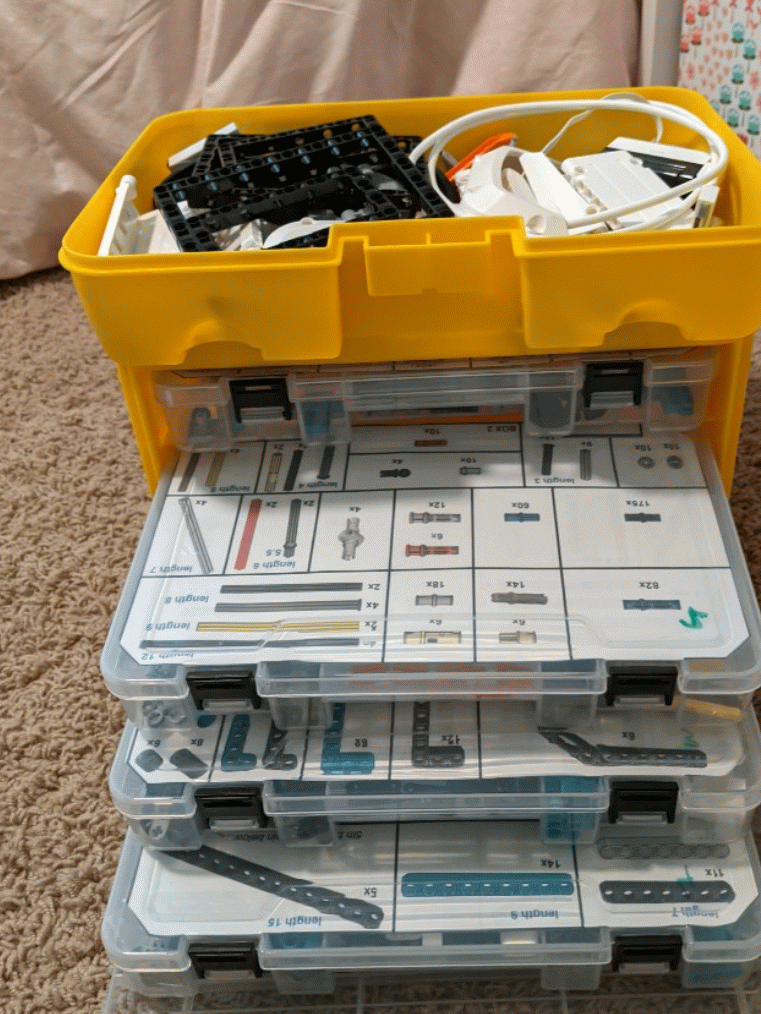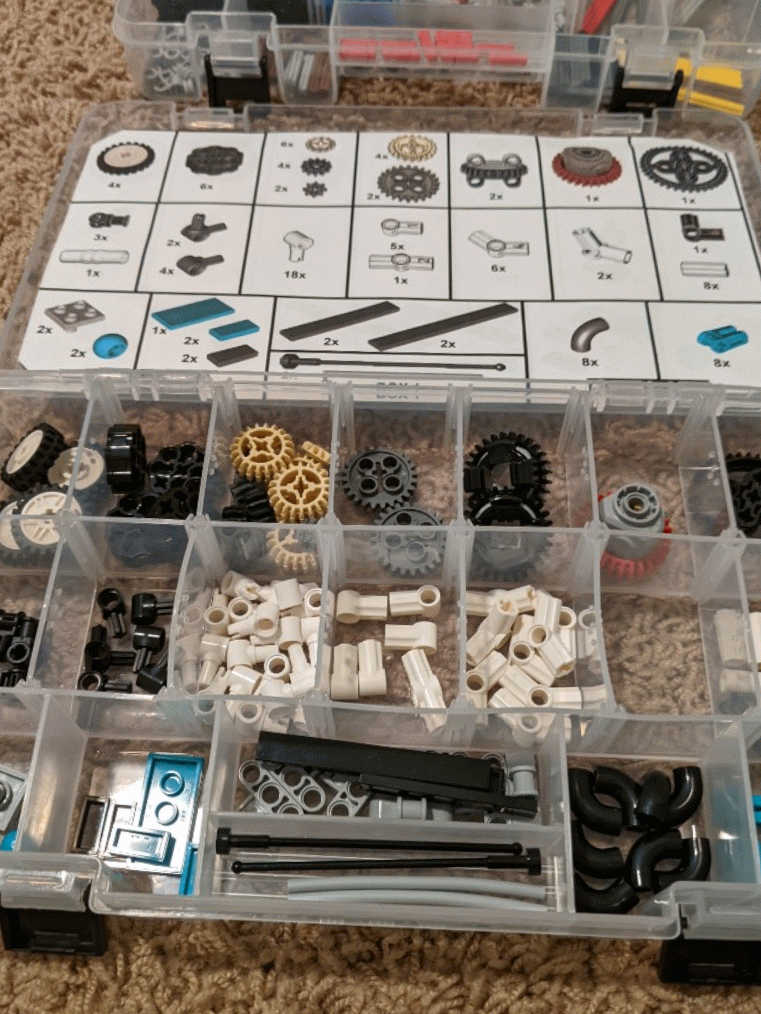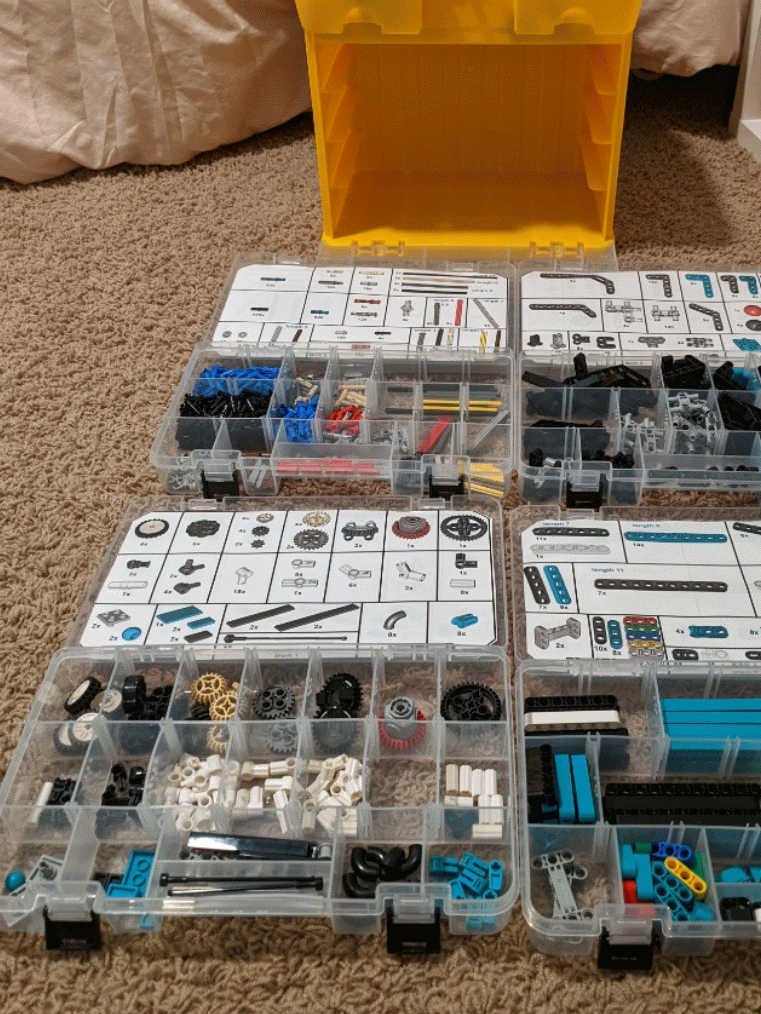
Organizer/Storage for Lego Robot Inventor Kit (Mindstorms) 51515


Ever since I got my kid the Lego Robot Inventors 51515 kit, I have been looking for a good way to store the pieces and I think I have finally found the solution thanks to www.RoboticsLearning.com!

On that website, I found a link to a storage organizer system sold at Harbor Freight: Storehouse Toolbox organizer with 4 drawers. If you dont have a harbor freight near you, I think these from Amazon are similar organizer systems:

ABN Tool Box, 10in 1pk - 4 Drawers Toolbox Organizers and Storage, Toolkit Workbench Garage Organizing Set Plastic Chest - - Amazon.com

VonHaus Multi-purpose Small Parts, Crafts or Tool Organizer/Storage Box - 4 Removable Trays & Adjustable Dividers (10.9 x 10.1 x 6.9 inches - Black/Orange) - - Amazon.com

Here are some images of my organized 51515 kit:

https://photos.app.goo.gl/bxrgZ6fAAvpn5eyG7

Here is where you can buy the labels ($10 for the PDF) and find more information on RoboticsLearning.com: LEGO Robot Inventor Set Case Label PDF Files (roboticslearning.com)

Update (11/29/2022): Here is how you can use the above storage box to organize the Spike Prime Kit: https://docs.google.com/presentation/d/10Esa5g_wjFTve83ESnl0FsqPti4y4rMp9Yz4-k-3rP4/edit?usp=sharing

Monday, May 02, 2022

GitHub - Quickly create a patch file

Recently I had to create a patch file to submit to an open source project.

Here is a quick way to do it via the GitHub web-pages.

  1. Go to your pull request (eg: https://github.com/pentaho/pentaho-kettle/pull/8283)
  2. Add ".patch" to the end. Click enter.
  3. This will redirect you to a new page with the patch info with some additional email info, etc.
  4. Copy the entire text and paste it into a file. Save the file with an extension of .patch.
  5. I found that I needed to add a new line at the end of the patch file.
That is your patch file!

To apply the patch file:
  1. Create a new branch from master (or whichever branch the patch is to be applied to).
  2. Switch to the branch.
  3. Run the following command: git apply name_of_patch_file.patch
If you instead want to manually create your patch using GIT:
  1. Switch to the branch with your changes
  2. Run the following command: git diff master > ..\name_of_patch_file.patch


Wednesday, April 27, 2022

AWS Athena's Information_Schema

The information_schema in most database systems is very useful to get information about tables, views, columns that might be available in that db.

Here are the information schema views available. (WARNING: queries against the information_schema views are very slow)


 Schemas:

SELECT

  catalog_name,  schema_name

FROM information_schema.schemata

 Tables:

SELECT

  table_catalog,  table_schema,  table_name,  table_type

FROM information_schema.tables

Columns:

select

  table_catalog,  table_schema,  table_name,  column_name,  data_type,  is_nullable,

  column_default,  comment

from information_schema.columns

order by

  table_catalog,  table_schema,  table_name,  ordinal_position


Retrieved by looking at the PrestoDB test cases: presto/presto-product-tests/src/main/resources/sql-tests/testcases/system at 2ad67dcf000be86ebc5ff7732bbb9994c8e324a8 · prestodb/presto · GitHub 

Pentaho Data Integration - Java Defined Class - Main working sample

 The sample code provided in PDI for "main" doesnt work. Here is the fixed up version:

mypublicnotes/Sample-UserDefinedJavaClass-Main.md at master · rajrao/mypublicnotes (github.com)

Pentaho Data Integration - Stripping characters out of string fields

 Here is a generic method (actually 2) for stripping out characters from all string fields in Pentaho.

mypublicnotes/Sample-Generic-Input-FieldFixerUpper.md at master · rajrao/mypublicnotes (github.com)

These methods are convenient when you are loading a variety of tables or files and you dont know the names of all the string fields ahead of time and so cannot use field based transformations (like Replace in String, etc).

Thursday, February 17, 2022

PowerBi Icons for Diagrams

 I found a couple of awesome resources for PowerBi icons that you can use in diagrams.

1. Official repo of PBI icons: microsoft/PowerBI-Icons: Icons (PNG and SVG) for Power BI (github.com)

2. Marc Lelijveld repo: Marc has provided an xml document that allows you to easily import all the icons into Draw.Io. This makes the whole process extremely easy. marclelijveld/Power-BI-Icons: Icons (PNG and SVG) for Power BI (github.com). The most import link from Marc's repo is the raw link to the xml file: https://raw.githubusercontent.com/marclelijveld/Power-BI-Icons/main/Diagrams.net_PowerBIIcons.xml. This link can be used in Draw.Io via File >>Open Library from >> URL...

Once done, you will get all the icons in the left pane:


Here is more info from Marc's blog: Power BI Icon Library – now includes official icons to use in Draw.io / Diagrams.net – Data – Marc (data-marc.com)

Saturday, January 29, 2022

Kids.youtube.com activate not working

The kids YouTube activation site (https://kids.youtube.come/activate) doesn't seem to be working. I was able to sign in via https://accounts.google.com/o/oauth2/device/usercode?flowName=DeviceOAuth

With 2 kids at home, I feel like a catastrophe has been averted. Hope it helps you.


Thursday, January 27, 2022

Emails from PowerBi.com service dont go to Email Groups

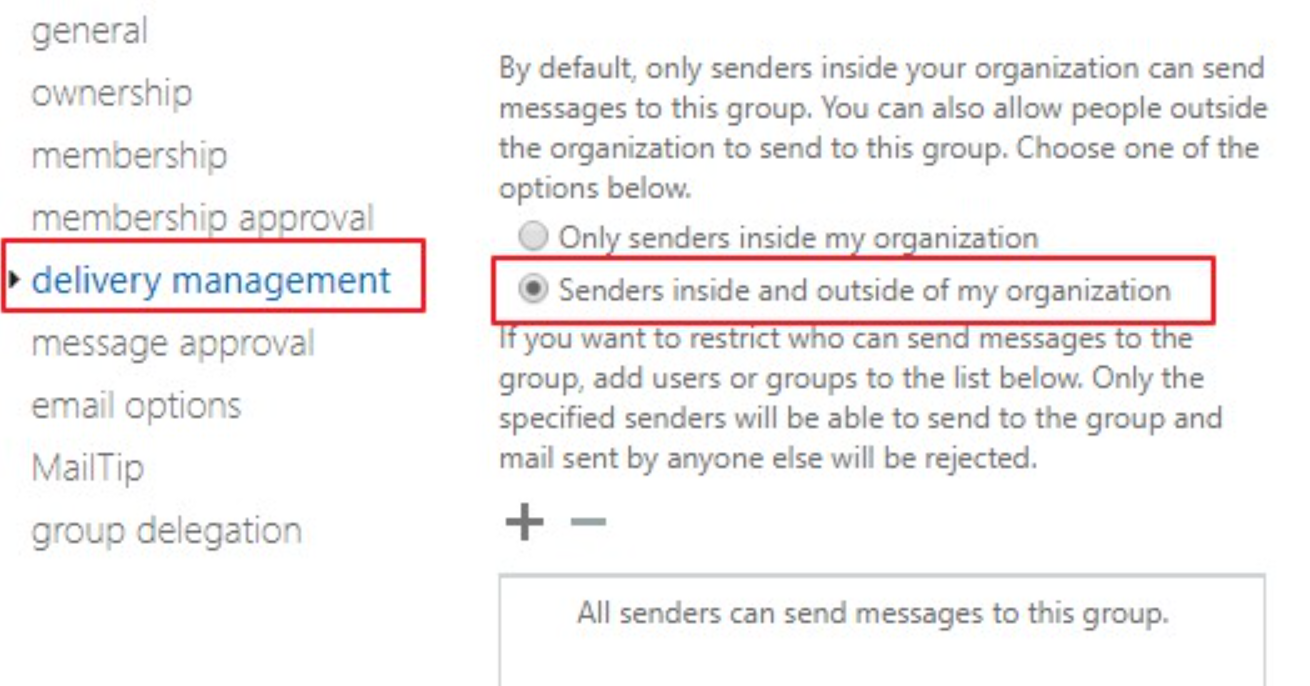
If you use a distribution group for emails in PowerBi.com (eg: Subscriptions to reports or to Dataset refresh issues), you might find that you dont receive the emails if you are using Office365. This is likely because by default Distribution Lists in O365 disable receiving emails from external addresses and this has to be enabled.

To receive emails from PowerBi, you have to enable receiving emails from external senders. You need to enable the option: "Senders inside and outside of my organization". This can be done by following the instruction here: https://docs.microsoft.com/en-us/Exchange/recipients/distribution-groups?view=exchserver-2019#delivery-management.